Runway releases open-weight robot control model trained on video data
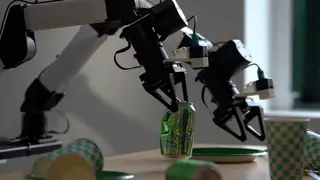
Runway AI unveiled Praxis-1, an open-weight world action model that leverages large-scale video pretraining to enable robot control without requiring extensive robot-specific demonstrations. The model learns from third-person video footage to understand object behavior and task progression, with performance improving as more video data is incorporated. Runway has been testing Praxis-1 with partners and plans public release in the coming months.
Runway's approach addresses a fundamental challenge in robotics development: the scarcity and high cost of collecting robot-specific training data. By leveraging the vastly larger corpus of publicly available video footage, the company believes it can train more capable control systems without requiring thousands of hours of teleoperated demonstrations. The firm claims its simulation-based approach achieves strong correlation with real-world outcomes, suggesting that video-derived understanding translates effectively to physical robot performance.
Early testing with multiple robotics partners indicates the model's flexibility across different hardware platforms. The ability to adapt a single trained model to diverse robot designs—from multi-armed systems to humanoid forms—through minimal additional fine-tuning could accelerate development cycles for robotics companies, potentially lowering barriers to entry for smaller firms developing specialized applications.
Praxis-1's public availability could reshape how robotics companies approach control system development, potentially democratizing access to advanced robot training capabilities. If the model performs reliably across diverse embodiments, manufacturers and research labs may reduce dependence on proprietary data collection, lowering development costs. However, the actual impact depends on real-world performance at scale and whether the model generalizes beyond the manipulation tasks demonstrated thus far. Broader adoption could accelerate physical AI deployment in industrial and commercial sectors.