NVIDIA's Isaac ROS 5.0 adds AI-agent workflows to speed robot software creation
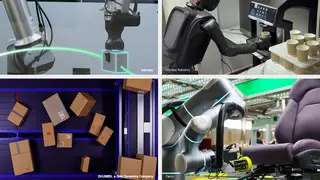
NVIDIA unveiled Isaac ROS 5.0 at ROSCon in Toronto, introducing agentic workflows and support for ROS 2 Lyrical and Ubuntu 24.04. The update aims to reduce development friction by automating setup, environment configuration, and repetitive tasks like fine-tuning. Early adopters include Intrinsic, Mentee Robotics, EKUMEN, and Flexiv.
The release targets roughly 1.3 million ROS users, with NVIDIA collaborating alongside the Open Source Robotics Alliance to identify common development pain points. Beyond agentic workflows, the update adds compatibility with ROS 2 Lyrical and Ubuntu 24.04, plus a standard data-handling interface contributed to ROS 2 that operates across GPU and non-GPU hardware, with CUDA serving as the acceleration example.
Early adopters include Intrinsic, Mentee Robotics, EKUMEN, and Flexiv, while Magna is pairing Isaac ROS with Isaac Sim for hardware-in-the-loop testing. New Isaac Skills packages provide reusable workflows for setup and manipulation tasks, and agent-ready documentation is designed to help AI agents navigate the framework's structure and capabilities.
The introduction of AI agents into robotics development could lower entry barriers for smaller teams and individual developers who lack dedicated infrastructure expertise. By automating setup and fine-tuning, this may accelerate prototyping cycles across manufacturing, logistics, and service robotics. However, reliance on NVIDIA's GPU ecosystem could deepen dependencies on proprietary hardware, potentially shaping how open-source robotics tools evolve and who can fully participate in their advancement.