Gemini Robotics 2.5 Boosts Real-World Robot Agility and Precision
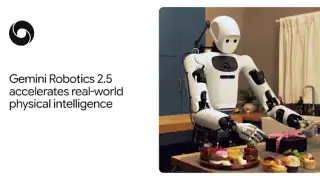
Gemini Robotics 2.5 introduces significant improvements in how robots perceive, plan, and execute physical tasks in dynamic environments. The model enhances real-time decision-making, allowing for smoother and safer interactions with complex, unstructured settings. These advances mark a leap toward more autonomous and adaptable robotic systems.
Gemini Robotics 2.5 represents a notable advancement in multimodal model research, specifically tailored to enhance robotic performance in real-world environments. The model introduces significant improvements in how robots interpret sensory input, formulate action plans, and carry out physical tasks with greater agility and precision. These upgrades enable robots to make faster, more reliable decisions in dynamic and unstructured settings—such as crowded public spaces or evolving industrial workflows—where traditional systems often struggle due to unpredictability. While specific details such as release dates, deployment locations, or performance benchmarks are not provided, the emphasis on real-time decision-making underscores a shift toward more autonomous and responsive robotic agents.
The development builds on prior progress in multimodal AI, where models integrate visual, auditory, and spatial data to understand complex environments. Earlier versions of Gemini Robotics likely laid the groundwork for this iteration, suggesting an ongoing effort by its developers to bridge the gap between theoretical AI capabilities and practical physical interaction. The focus on unstructured environments indicates a strategic pivot from controlled lab settings toward real-world usability—addressing long-standing challenges in robotics that have limited widespread adoption.
The primary organization behind this development is not named, but the model’s architecture implies deep integration with broader AI research ecosystems, possibly involving tech giants or specialized robotics firms. These entities likely seek to expand robotic applications across industries such as logistics, healthcare, and manufacturing, where adaptability and safety are paramount. However, key questions remain: how widely will this model be deployed, what hardware requirements does it impose, and how do its decision-making processes ensure reliability under stress? The path forward may involve further testing in diverse environments, regulatory scrutiny, or integration with existing automation platforms—details not yet disclosed.
Gemini Robotics 2.5 could significantly influence how robots interact with humans in shared spaces, potentially reshaping labor dynamics in sectors like warehousing and elder care. As robots become more adept at navigating unpredictable physical environments, they may take on roles previously deemed too complex for automation, raising concerns about job displacement and the need for workforce retraining. Industries reliant on manual labor may see accelerated adoption of autonomous systems, altering supply chains and service delivery models. A comparable precedent is the rollout of self-driving car technology, which initially promised transformative mobility but faced delays due to safety concerns and regulatory hurdles. Like that case, widespread trust in robotic autonomy will depend not just on technical prowess but on transparency and accountability in decision-making. The broader AI community may also respond with new standards for evaluating real-world robustness in multimodal systems. What to watch for includes pilot programs in high-traffic environments, third-party audits of safety performance, and public discourse around the ethical boundaries of autonomous physical agents. The model’s success could catalyze investment in adjacent fields like sensor fusion and edge computing—areas critical to real-time operation.